Research and projects

Selected Work

Graduate research and engineering projects in autonomous navigation, computer vision, SLAM, motion planning, and robot control.

Red and blue graph representation used in an autonomous-navigation representation experiment
UC San Diego graduate research

RL for Autonomous Navigation

At the Existential Robotics Laboratory, I built a custom MuJoCo and dm_control environment for an Ackermann-drive vehicle to study PPO and SAC policies, obstacle generation, collision handling, reward behavior, and learned visual representations.

  • MuJoCo
  • dm_control
  • Stable-Baselines3
  • PyTorch

Graduate research · UC San Diego · representation-work visual, not simulator footage
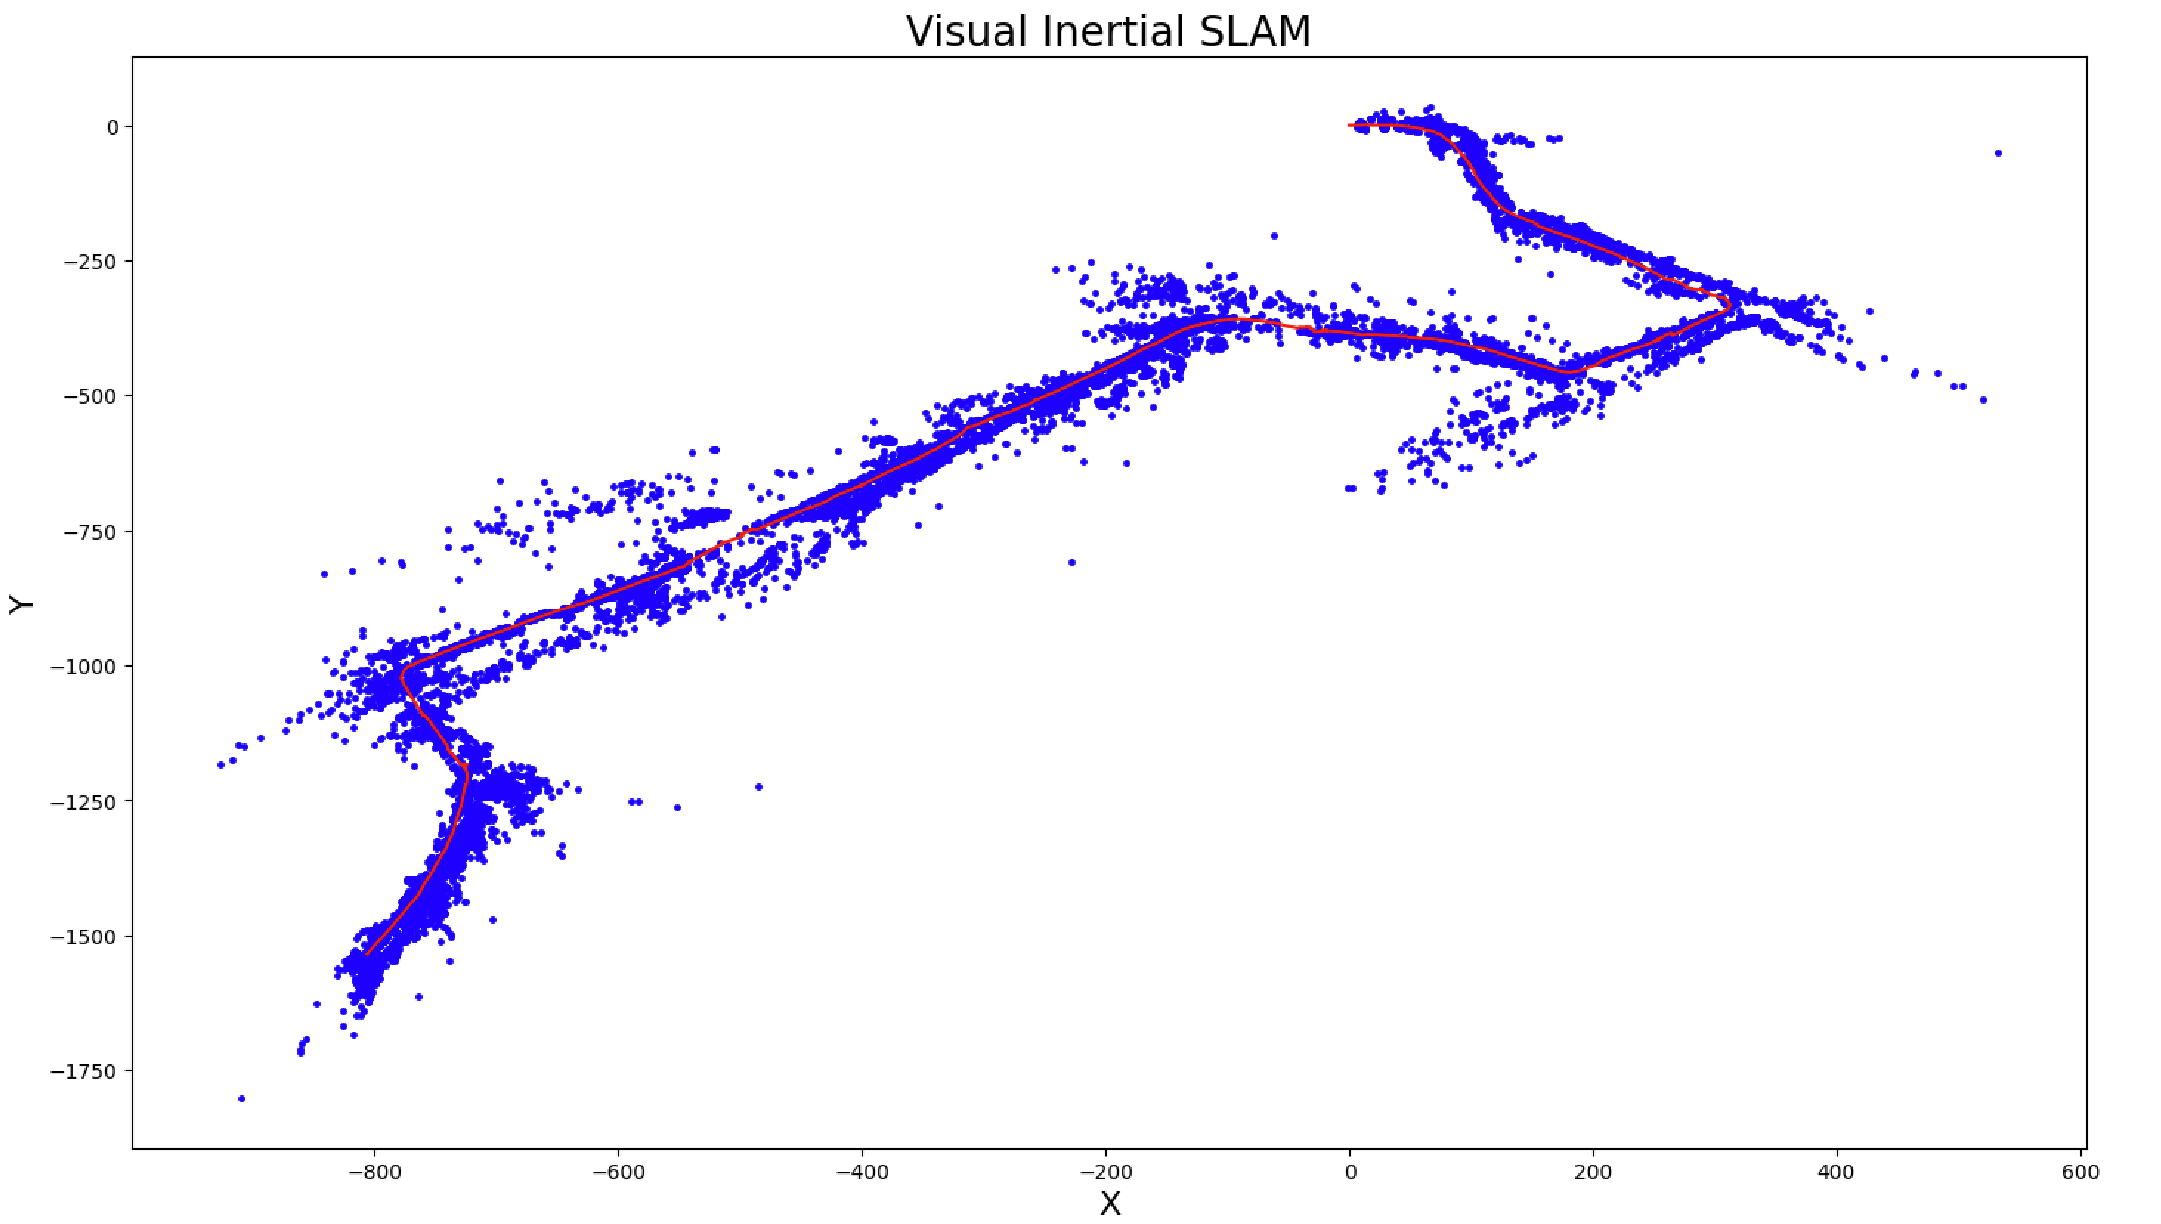
Visual-inertial SLAM landmark map with an estimated vehicle trajectory
State estimation / Sensor fusion

Visual-Inertial SLAM

An EKF-based pipeline that fused IMU measurements and stereo observations for vehicle pose estimation and landmark mapping, with the mathematical derivation and implementation documented in the project report and repository.

  • Python
  • EKF
  • Stereo vision
  • IMU
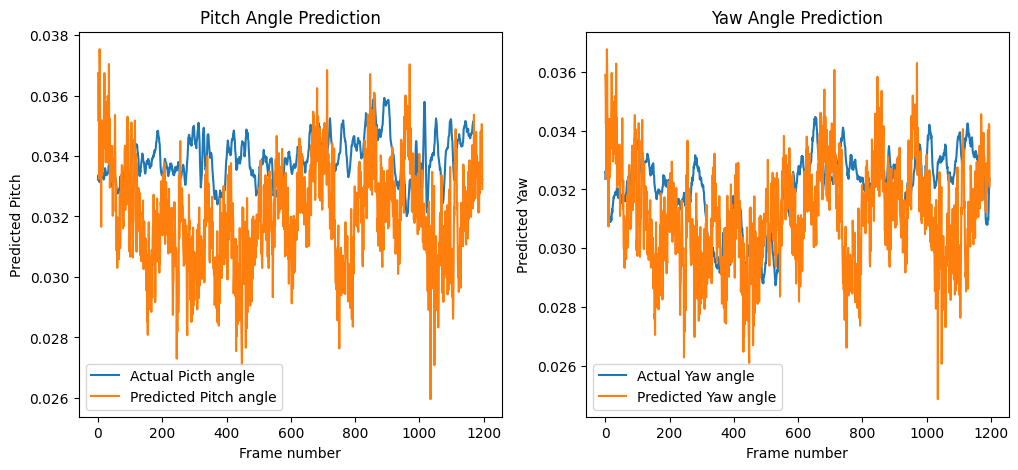
Plots comparing ground-truth and predicted pitch and yaw for the camera-calibration project
ECE 228 team project / Computer vision

Comma.ai Calibration Challenge

An ECE 228 team project for the Comma.ai Calibration Challenge, combining optical flow, vanishing-point cues, convolutional features, and an LSTM to estimate camera pitch and yaw from driving video.

  • PyTorch
  • Conv-LSTM
  • Optical flow
  • OpenCV
Additional projects

Coursework and engineering projects

Projects in mapping, planning, optimal control, and manipulation, with reports and source code where available.

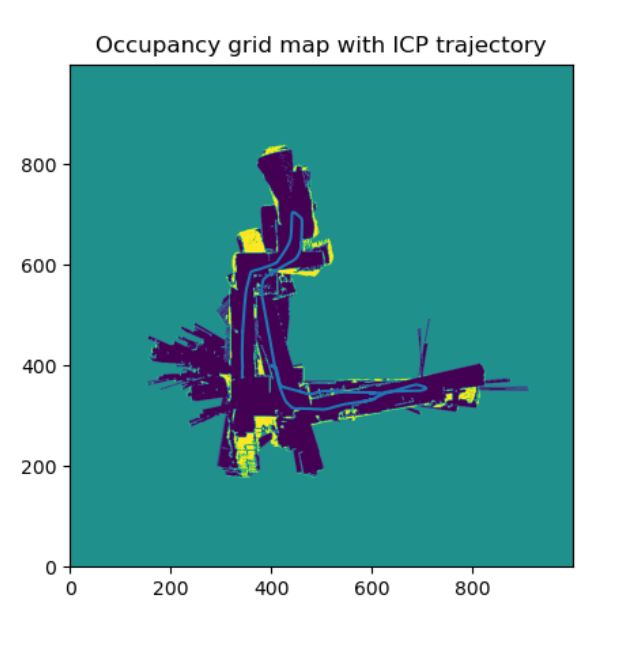
Occupancy-grid map produced by the LiDAR SLAM pipeline
Mapping / Localization

LiDAR SLAM

Multi-sensor odometry, ICP scan matching, occupancy-grid mapping, and pose-graph optimization for a differential-drive robot.

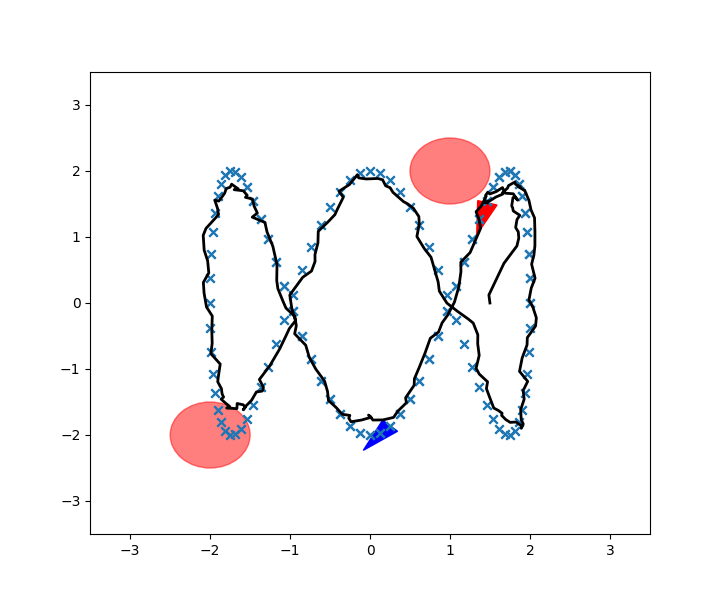
Trajectory-tracking result from the stochastic optimal-control project
Optimal control / Uncertainty

Infinite-Horizon Stochastic Control

Certainty-equivalent control and generalized policy iteration for noisy trajectory tracking and obstacle avoidance.

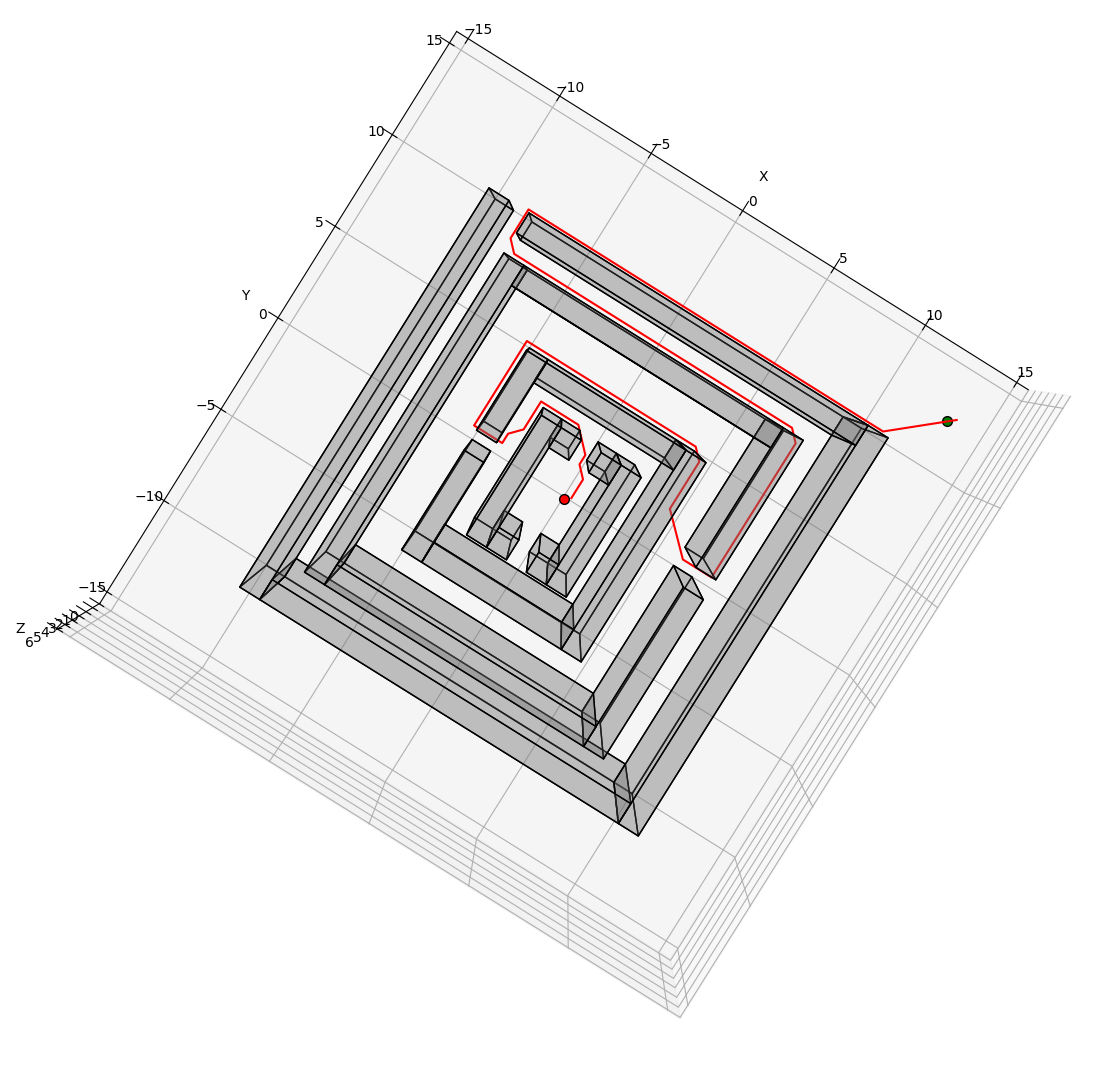
Three-dimensional obstacle environment used to compare A-star and RRT planning
Motion planning / Collision checking

A* and RRT in 3D

A comparison of search-based and sampling-based collision-free path planning in continuous three-dimensional environments.

Animated Door and Key grid-world policy execution
Dynamic programming / MDP

Door & Key Navigation

A dynamic-programming policy for key pickup, door unlocking, and minimum-cost navigation across fixed and random grid maps.

CoppeliaSim animation of a YouBot mobile manipulator completing a pick-and-place task
Robot control / Manipulation

YouBot Mobile Manipulation

Kinematics, reference-trajectory generation, and feedforward-plus-PI feedback control for a simulated pick-and-place task.

IMU and camera sensors used for orientation tracking and panorama construction
Sensor calibration / Geometry

Orientation Tracking & Panorama

IMU bias calibration, quaternion kinematics, projected-gradient optimization, and camera-image stitching.

Remote startup teams

Need someone who can move between robot behavior and implementation detail?

Start a conversation