Robotics & Applied ML Engineer

ROBOTICS AND
APPLIED MACHINE
LEARNING.

Graduate research and projects in autonomous navigation, computer vision, SLAM, motion planning, and robot control.

M.S., UC San Diego B.Tech., IIT Bombay
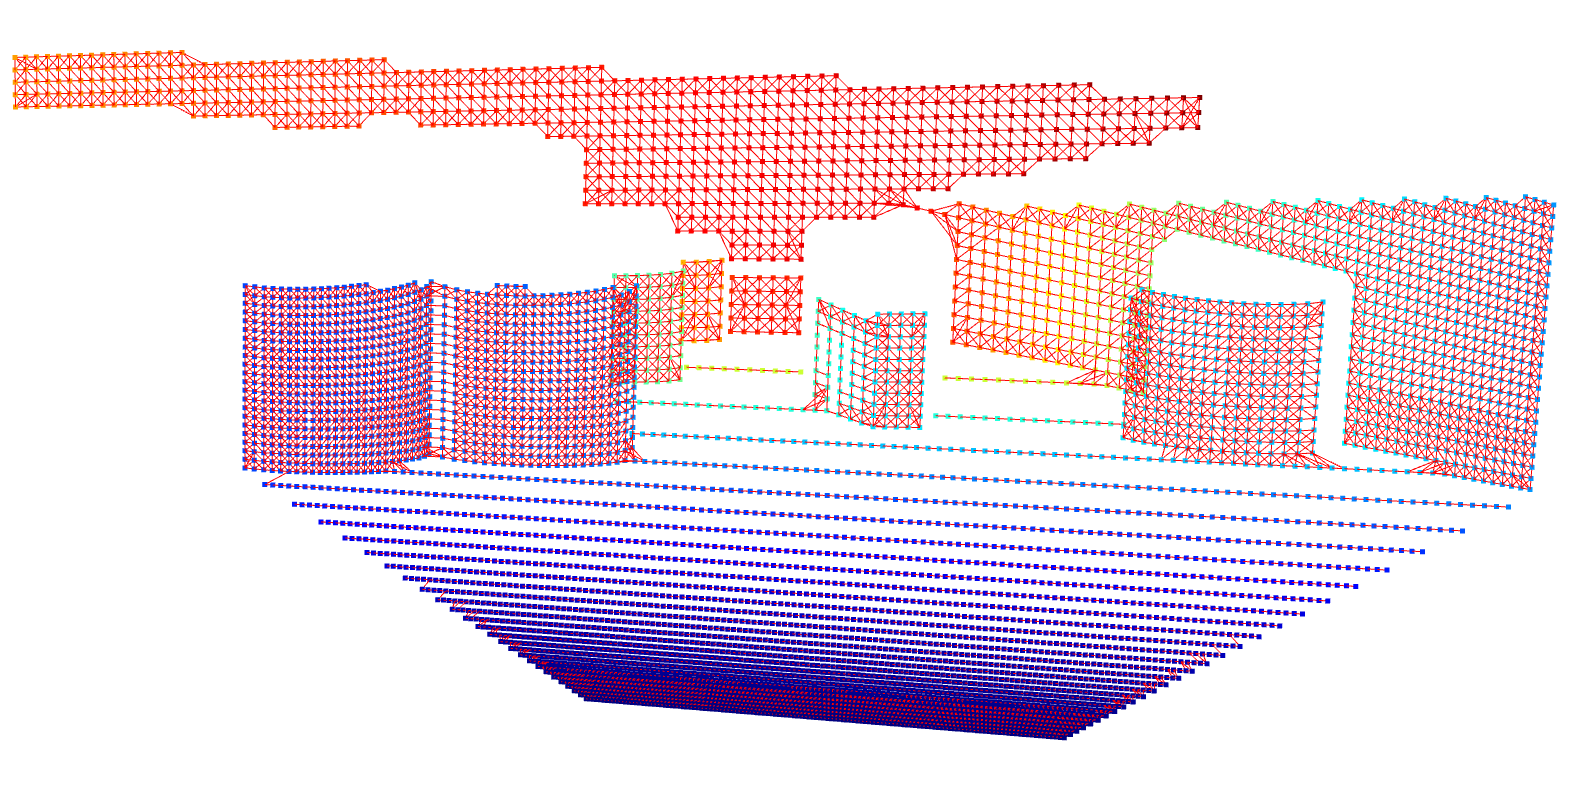
Static red-and-blue navigation graph visualization from the autonomous navigation research archive.
Project
RL for Autonomous Navigation
Institution
UC San Diego

Selected work

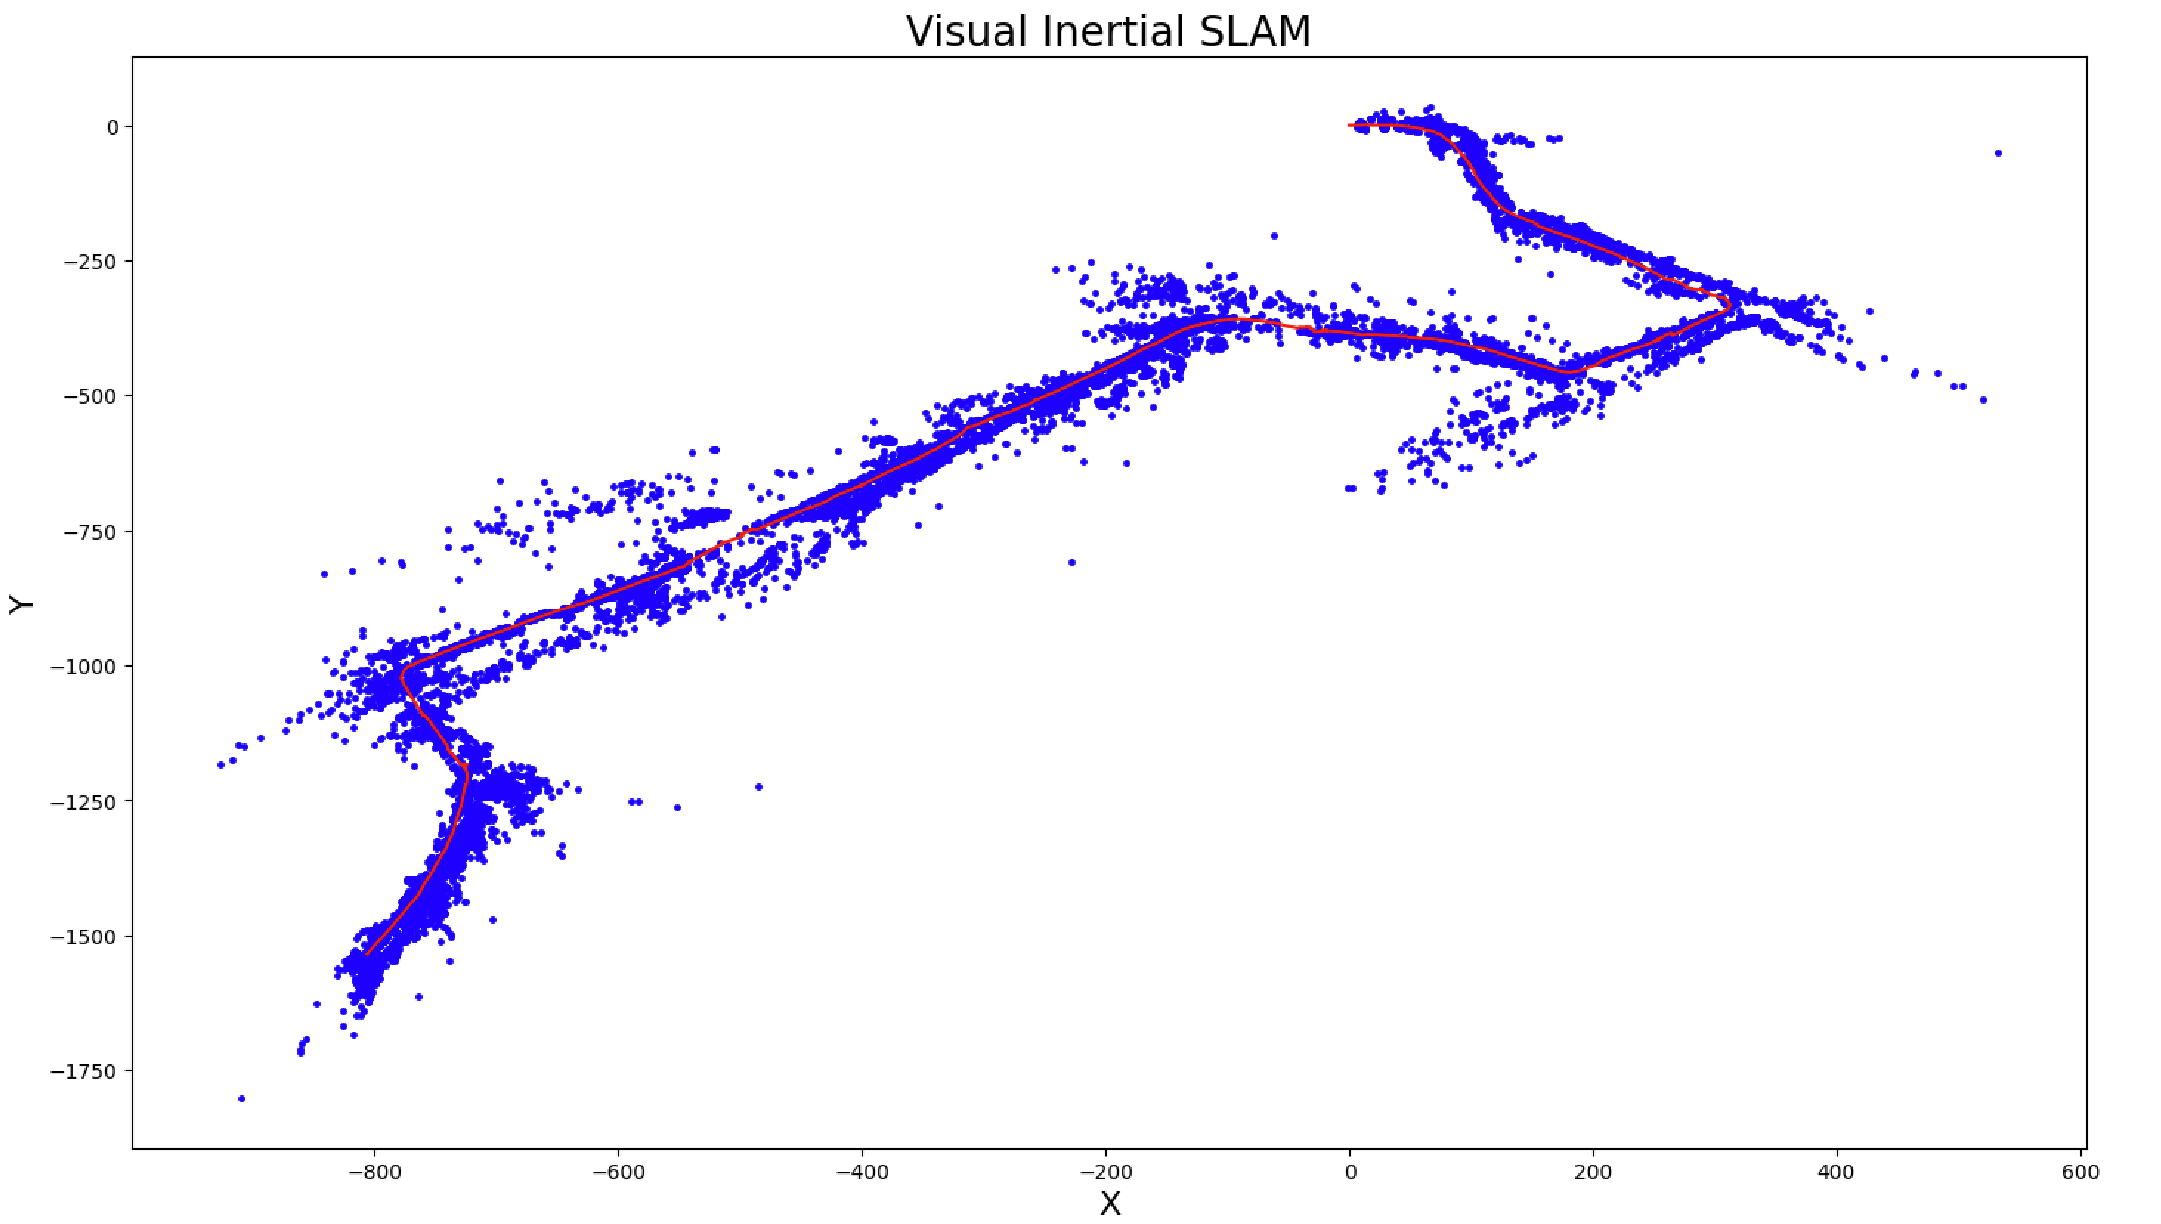
Visual-inertial SLAM trajectory and landmark map

02 · State estimation / Mapping

Visual-Inertial SLAM

Fused stereo observations and IMU measurements with an extended Kalman filter to estimate motion and build a landmark map.

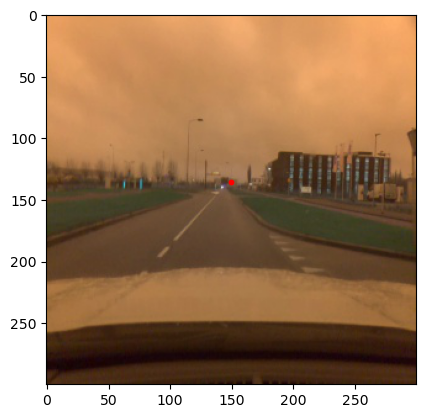
Road scene annotated with a vanishing point for camera calibration

03 · ECE 228 team project

Comma.ai Calibration Challenge

An ECE 228 team project for the Comma.ai Calibration Challenge, combining optical flow, vanishing-point geometry, and a Conv-LSTM model to estimate camera pitch and yaw from monocular driving video.

Based in India · Open to remote startup teams · View all projects

Background

Mechanical engineering to robotics.

Based in India · Open to remote startup teams

My path began with mechanical engineering and hands-on robotic systems, then moved through estimation and perception into learning-based decision-making. Graduate research at UC San Diego's Existential Robotics Laboratory focused on reinforcement learning for autonomous navigation under Prof. Nikolay Atanasov.

My work combines software with physical-system constraints such as sensor noise, vehicle dynamics, collision risk, and compute limits.

  • Learning-based navigation Simulation environments, PPO/SAC, reward design, and evaluation.
  • State estimation & mapping Visual-inertial and LiDAR SLAM, filtering, mapping, and sensor fusion.
  • Vision & temporal models Optical flow, CNNs, LSTMs, and calibration from video.
  • Robotics implementation Python, PyTorch, MuJoCo, technical debugging, and system integration.

Contact

Interested in robotics or applied ML work?

Contact me